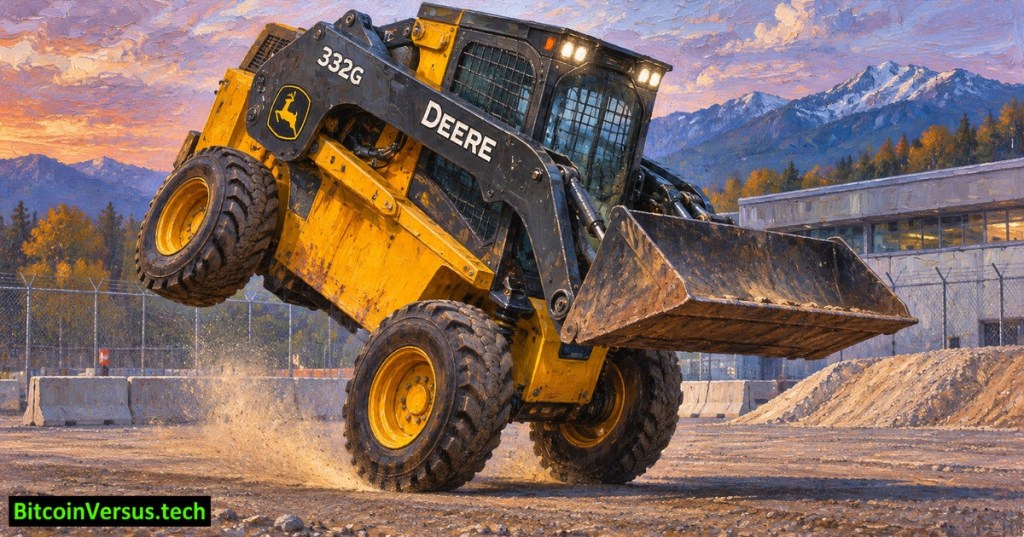
A 5-tonne John Deere 332G loader has learned a stunt that normally requires an expert operator: lifting its rear wheels, balancing on its two front wheels, driving over rough ground and setting itself safely back down. Researchers from ETH Zurich and collaborators reported the autonomous demonstration in Science Robotics on November 11, 2026. The team trained the control system through simulated experience rather than making the real machine learn by repeatedly falling over.
The published study, “Heavy metal acrobatics: Learning dynamic control for skid-steer loaders,” describes more than a staged wheelie. The loader followed target trajectories, spun while upright and moved its hydraulic bucket arm without losing balance. Actual experiment footage, including tests on uneven ground, is available on the researchers’ original project page.
ETH Zurich Robotic Systems Lab’s May 27, 2026 video demonstrates reinforcement learning on a different 12.5-tonne excavator. Background research only. For direct footage of the new five-tonne loader, see the authors’ research video collection.
How a heavy loader learns to balance
Heavy machines are difficult to control precisely because a hydraulic system does not behave like a perfectly responsive electric motor. Fluid movement, friction, flexible mechanical elements and delayed actuator responses all complicate the calculation of how a machine will move after a command. The machine’s mass makes uncontrolled physical trial and error especially hazardous.
The team first characterized the loader’s dimensions, center of mass and hydraulic responses, collecting approximately 90 minutes of data from the real machine, according to DongA Science’s technical account. Researchers then built a simulated representation and used reinforcement learning to teach control policies how to tip, balance, travel and land. During training, the simulation varied physical parameters and sensor errors to improve the policy’s ability to transfer to hardware.
The result is an example of sim-to-real robotics: software rehearses difficult behavior virtually before commanding a real machine. Separate learned motion stages handle the transition onto two wheels, ongoing balance, movement speed and the return to four wheels. The experiment shows coordination of drivetrain forces with the bucket arm’s shifting mass.
Testing the limits
Reported field tests reveal both impressive results and a meaningful limit. At bucket-arm settings of 28 and 31 degrees, the machine successfully rose onto two wheels in 11 of 11 and 12 of 12 trials, respectively. At 34 degrees, outside the training range, it succeeded in 11 of 14 attempts, approximately 78.6%. Those small samples are specific tests, not evidence of a general 78.6% success rate on construction sites.
ETH Zurich Robotic Systems Lab’s original 2022 demonstration of soil-adaptive autonomous excavation. The related work provides historical context for learned hydraulic controls and is not video of the 2026 skid-steer experiment.
The loader also navigated an uneven course including a mound roughly 75 centimeters high, despite its balancing policy being trained on level ground. Onboard measurements of motion and wheel speed helped control the maneuver, rather than a camera or lidar system mapping obstacles ahead. Researchers reported running the deployed controller on an ordinary Intel Core i7 laptop with 16 GB of memory.
Why a wheelie matters for construction
An autonomous two-wheel stunt is not the same as a certified commercial self-driving loader. Real construction sites introduce nearby workers, moving vehicles, debris, soft soil and uncertain visibility. The paper demonstrates precise dynamic stabilization in research conditions; safe unsupervised operation would require robust perception, operational safeguards, extensive validation and clear human oversight.
Still, balance control could eventually contribute to terrain recovery, challenging loading operations and navigation on uneven worksites. ETH Zurich’s related robotics ecosystem has pursued more conventional construction autonomy as well, including research that led to commercial excavator systems. The immediate breakthrough concerns the level of dynamic control achieved on a large hydraulic machine, not a promise that future loaders should perform wheelies during normal work.
Readers following robotics developments may also recognize related but distinct advances in ETH Zurich’s Rubik’s Cube-solving ANYmal, UC San Diego’s fast air-powered soft robot, Kajima’s construction robotics deployments and Boston Dynamics’ wheeled Atlas experiments. Different mechanical platforms demand different control strategies, but all illustrate the movement from lab simulations toward physical machines.
The deeper lesson is that practical automation depends on controlling forces and momentum, not only recognizing objects. A loader that can stabilize a five-tonne body during extreme motion illustrates how far robot control has progressed, while showing why rigorous safety testing remains the next challenge.
Primary research and original video
- Science Robotics, November 11, 2026, Heavy metal acrobatics: Learning dynamic control for skid-steer loaders
- ETH Zurich institutional research record and author list
- ETH Zurich researchers’ original video gallery with loader demonstration and supplementary tests
- Author manuscript, posted November 13, 2026
- DongA Science, November 12, 2026, additional laboratory test details
- ETH Zurich Robotic Systems Lab, May 27, 2026, related excavator control demonstration
Editor’s Note: We volunteer daily to ensure the credibility of the information on our platform is Verifiably True. If you would like to support our work and the integrity of our research initiatives, scan the QR code below to donate 5,000 sats.

For mobile scanning, open the article on another display and scan the QR code using a Bitcoin wallet. Verify the receiving address 3C9o19EH5HSiwEPyCTmEKzxhNCbo2X6TTb before sending.
BitcoinVersus.Tech reports technology, engineering and robotics research for informational purposes. The experimental loader maneuvers shown in the cited research are not instructions for equipment operators; machinery must be used within applicable safety procedures and manufacturer limits.


Leave a Reply