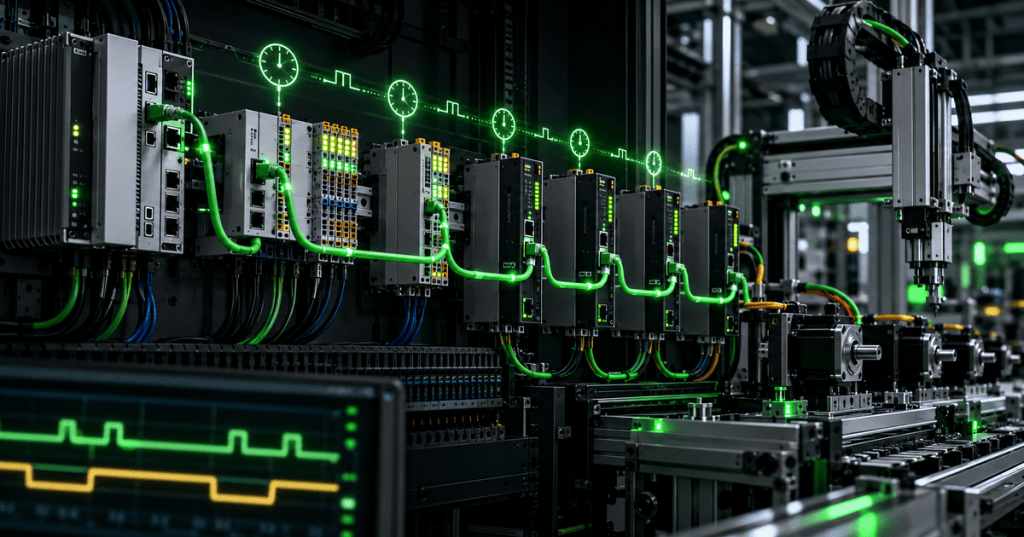
EtherCAT is a real-time Industrial Ethernet system built for fast, deterministic communication between a controller and distributed field devices. For an electrical technician, the key ideas are understanding how one Ethernet frame is processed as it passes through devices, why topology matters, how Distributed Clocks synchronize motion, what the Working Counter tells you, and how to isolate a physical fault from a configuration or timing fault.
This lesson follows OSETC.035: PROFINET Basics, OSETC.034: EtherNet/IP Basics, and OSETC.033: Modbus TCP over Ethernet. EtherCAT is another Industrial Ethernet technology, but its traffic flow and timing model are different enough that technicians should not troubleshoot it as if it were ordinary switched Ethernet.
RealPars gives a technician-friendly overview of EtherCAT and explains why on-the-fly frame processing is different from ordinary Ethernet communication.
What You’ll Learn
- Explain what EtherCAT is and how it differs from normal switched Ethernet.
- Describe on-the-fly frame processing.
- Identify the master and slave roles.
- Understand line, tree, star, and ring-style EtherCAT topologies.
- Explain the purpose of EtherCAT Slave Information files.
- Recognize INIT, PRE-OP, SAFE-OP, and OP device states.
- Explain Distributed Clocks and why synchronized motion depends on them.
- Understand the Working Counter and what a mismatch indicates.
- Use a repeatable field troubleshooting workflow.
- Recognize common cabling, topology, configuration, and timing faults.
EtherCAT Is Ethernet, but It Does Not Behave Like a Normal Ethernet LAN
EtherCAT uses standard Ethernet physical technology, but the communication principle is optimized for automation. The EtherCAT Technology Group describes EtherCAT as an open real-time Ethernet network originally developed by Beckhoff. Instead of sending a separate application frame to every device and waiting for individual responses, the controller can send a frame through the network while each EtherCAT slave reads or writes only the data assigned to it.
This difference matters in the field. A standard Ethernet switch learns MAC addresses and forwards frames between ports. EtherCAT normally uses devices with an IN and OUT path so the frame moves through the configured bus. Specialized EtherCAT junctions can create branches, but an ordinary office-style Ethernet switch should not be assumed to work as an EtherCAT branching device.
The Master and the Slaves
- EtherCAT Master: the controller that initiates EtherCAT frames, maintains the process image, monitors expected responses, and manages bus state.
- EtherCAT Slave: an I/O coupler, drive, encoder, servo, sensor interface, valve manifold, robot device, or other field device that processes relevant bytes as the frame passes through.
The master is the active communication authority. Slaves do not behave like independent Ethernet computers exchanging arbitrary traffic with one another. This centralized timing and frame model is one reason EtherCAT can achieve very short and predictable cycle times.
On-the-Fly Frame Processing
The defining EtherCAT idea is processing data while the Ethernet frame is moving through the device. Each slave controller examines the EtherCAT datagram, reads the bytes addressed to it, inserts its own input data where required, and forwards the frame downstream. The frame eventually returns to the master.
This avoids the store-and-forward behavior associated with normal Ethernet switching between every automation device. It also allows a single frame to carry process data for many devices. The EtherCAT Technology Group publishes examples showing hundreds or thousands of I/O points updated in extremely short cycle times because much of the protocol handling occurs in dedicated hardware.
EtherCAT Technology Group executive director Martin Rostan explains the core communication principle and why EtherCAT can move process data efficiently.
Topology Matters
EtherCAT can support line, tree, star, and combinations of these topologies when appropriate EtherCAT couplers or junction devices are used. Beckhoff documentation notes that a line or bus structure can be built without normal Ethernet switches because the EtherCAT interfaces are integrated into the devices. Specialized junctions create branches while preserving the EtherCAT processing model.
For technicians, physical order is important. If the project expects Master → Device A → Device B → Device C, but the field wiring is rearranged or a device is removed, the online topology can differ from the configured topology. That can create startup faults even when every cable is electrically good.
A PLC troubleshooting discussion shows why topology, missing slaves, device states, and Working Counter information are useful when an EtherCAT branch drops offline.
EtherCAT Slave Information Files
Engineering systems use an EtherCAT Slave Information, or ESI, file to describe a device. The XML-based information identifies the vendor, product, revision, process-data objects, synchronization capabilities, and other configuration details the master needs to recognize and configure the slave correctly.
A replacement device may look identical but use a different product revision or firmware combination. If the live hardware does not match the configuration expected by the master, the bus can stop during initialization or refuse to enter operational state. Always compare the exact device identity before assuming the cable is bad.
The EtherCAT State Machine
- INIT: the device has started but normal mailbox and process-data communication is not yet available.
- PRE-OP: mailbox communication and configuration can occur, but normal cyclic process outputs are not active.
- SAFE-OP: input data can be exchanged and checked while outputs remain in a safe condition.
- OP: full cyclic process-data exchange is active.
These states are valuable diagnostic clues. A slave stuck in INIT suggests a more basic discovery, identity, power, or link problem. A device that reaches PRE-OP but not SAFE-OP can point toward configuration or synchronization problems. A device that reaches SAFE-OP but refuses OP may be rejecting the requested output configuration or another operational condition.
Distributed Clocks
Fast communication is not enough for coordinated motion. Multiple drives also need a common time reference. EtherCAT Distributed Clocks allow compatible slaves to synchronize their local clocks to a network-wide timebase. The EtherCAT Technology Group documents synchronization accuracy significantly below one microsecond in properly designed systems.
This matters when several servo axes must sample positions or apply outputs at nearly the same instant. Without precise synchronization, timing jitter can appear as position error, velocity noise, poor coordinated motion, or unstable process measurements even though the network is technically communicating.
Beckhoff Automation explains Distributed Clocks and how EtherCAT synchronizes devices for precise real-time motion and measurement.
The Working Counter
Each EtherCAT datagram contains a Working Counter, commonly shortened to WKC. EtherCAT slaves increment the counter when they successfully perform the requested read, write, or read/write operation. The master knows what Working Counter value it expects for a healthy cycle and compares the returned value against that expectation.
If the returned Working Counter is lower than expected, one or more required interactions did not happen. That does not automatically identify the exact broken cable or failed device, but it tells the master that the process-data transaction was incomplete. Beckhoff documentation also exposes WcState variables so the controller can report whether cyclic communication was valid for a particular slave or SyncUnit.
Physical-Layer Checks Still Come First
EtherCAT can be extremely sophisticated, but a large percentage of field failures still begin with basic hardware: missing power, a damaged Ethernet cable, loose M8/M12/RJ45 connectors, contamination, incorrect shielding, a bad port, an unexpected junction, or a device that was moved during maintenance.
Before changing software configuration, record the original fault state and inspect the physical path. A configuration download can temporarily hide useful evidence or create a second fault. The safest troubleshooting sequence starts with observation and measurement before replacement or reconfiguration.
A Field Troubleshooting Workflow
- Start with safety. Follow the machine’s LOTO, safe-state, and access procedures before opening panels or disturbing field wiring.
- Read the controller diagnostics first. Record the master state, first missing slave, device state, Working Counter or WcState fault, and any topology mismatch.
- Check power. Verify the affected coupler, drive, or remote-I/O station has the required control and field power.
- Check link LEDs. Look for the first point in the physical chain where link or activity disappears.
- Inspect the cable path. Check connectors, cable damage, strain, bend radius, shielding, and recent maintenance work.
- Confirm IN and OUT orientation. Make sure the master enters the intended EtherCAT input port and downstream cabling follows the expected topology.
- Compare live and configured topology. Identify missing, swapped, or unexpected devices.
- Verify device identity. Compare vendor ID, product code, revision, firmware, and ESI information.
- Check the slave state. Determine whether the device is stuck in INIT, PRE-OP, SAFE-OP, or another faulted state.
- Check Working Counter information. A mismatch confirms that expected reads or writes are not completing.
- Check Distributed Clock faults when motion is involved. If all devices are online but synchronized motion is unstable, inspect DC status and timing configuration.
- Change one thing at a time. Document the original configuration before replacing hardware, changing topology, importing a new ESI file, or downloading a revised project.
Common EtherCAT Faults
- Missing slave: a powered-off device, cable break, failed port, or removed module interrupts the expected chain.
- Topology mismatch: the physical order or branch structure differs from the engineering project.
- Wrong device revision: the installed replacement does not match the configured identity.
- Wrong ESI file: the engineering environment has incomplete or incompatible device-description information.
- Slave stuck in SAFE-OP: the device can communicate but is not accepting the full operational configuration.
- Working Counter mismatch: expected process-data interactions did not all complete.
- Distributed Clock fault: synchronization requirements are not being met.
- Ordinary Ethernet switch inserted: the physical network was built as a normal LAN instead of the intended EtherCAT topology.
- Intermittent cable or connector: vibration or motion creates momentary link failures that may only appear in diagnostic counters.
Hands-On Exercise
- Use a training EtherCAT master with at least two slave devices or a simulator that exposes EtherCAT states.
- Draw the configured topology from master to the last slave.
- Record each device’s product identity and current EtherCAT state.
- Locate the Working Counter or WcState diagnostic in the engineering software.
- Record the healthy operational state and the expected Working Counter behavior.
- In a controlled training environment, disconnect the cable after the first slave.
- Observe which downstream devices disappear and how the master reports the topology and Working Counter fault.
- Reconnect the cable and confirm that the affected devices return through the state machine to OP.
- If the system supports Distributed Clocks, identify which device is the reference clock and review the synchronization status.
- Write a short field-service note describing the symptom, first useful diagnostic clue, root cause, and verification after repair.
Knowledge Check
- What does EtherCAT stand for?
- What is the main difference between EtherCAT frame processing and normal switched Ethernet?
- Which device initiates EtherCAT communication?
- Why does physical device order matter?
- What is an ESI file?
- What are the four main EtherCAT slave states?
- What problem do Distributed Clocks solve?
- What does the Working Counter indicate?
- Does a valid Ethernet link prove that the EtherCAT configuration is correct?
- Why should a technician record the original fault state before downloading a new configuration?
Answers
- Ethernet for Control Automation Technology.
- EtherCAT slaves process relevant data on the fly as a frame passes through the network instead of relying on ordinary store-and-forward switching between each device.
- The EtherCAT master.
- The configured topology determines which devices and paths the master expects to encounter.
- An XML-based EtherCAT Slave Information file describing a device’s identity, capabilities, and process-data configuration.
- INIT, PRE-OP, SAFE-OP, and OP.
- They provide a precise shared timebase so distributed devices can sample or act synchronously.
- It tells the master how many expected EtherCAT interactions completed successfully in a datagram.
- No. Physical link can be healthy while identity, topology, state, timing, or process-data configuration is wrong.
- Because changing configuration can erase diagnostic clues or introduce a second problem before the original root cause is understood.
Key Takeaway
EtherCAT troubleshooting is easiest when you separate the problem into four layers: physical path, topology and identity, EtherCAT state, and real-time timing. Start with power and link, verify the configured device chain, read the slave states and Working Counter, then move into Distributed Clock and timing analysis only when the basic bus is healthy.
References
Primary references: EtherCAT Technology Group — EtherCAT overview, EtherCAT Technology Group — technology brochure, Beckhoff — EtherCAT system properties and topology, and Beckhoff — Working Counter State.
Rotation next: C++.
Safety: industrial network troubleshooting may place technicians near energized control equipment, servo systems, and moving machinery. Follow site procedures, LOTO requirements, arc-flash boundaries, and approved diagnostic practices before opening enclosures, disturbing cables, or commanding motion.


Leave a Reply