technology
-
OSBash.001 introduces Bash shell and script basics: terminals versus shells, shebangs, running scripts with bash, chmod +x, ./ execution, PATH behavior, and first troubleshooting steps.
-
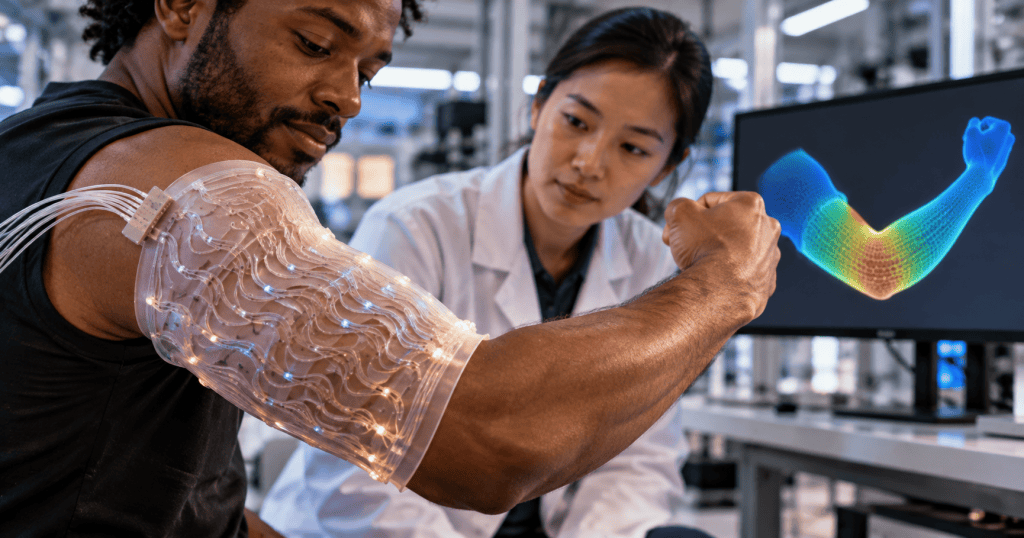
MIT engineers built a soft sensing sheet with embedded optical waveguides that can reconstruct its 3D shape as it bends, twists, and folds.
-
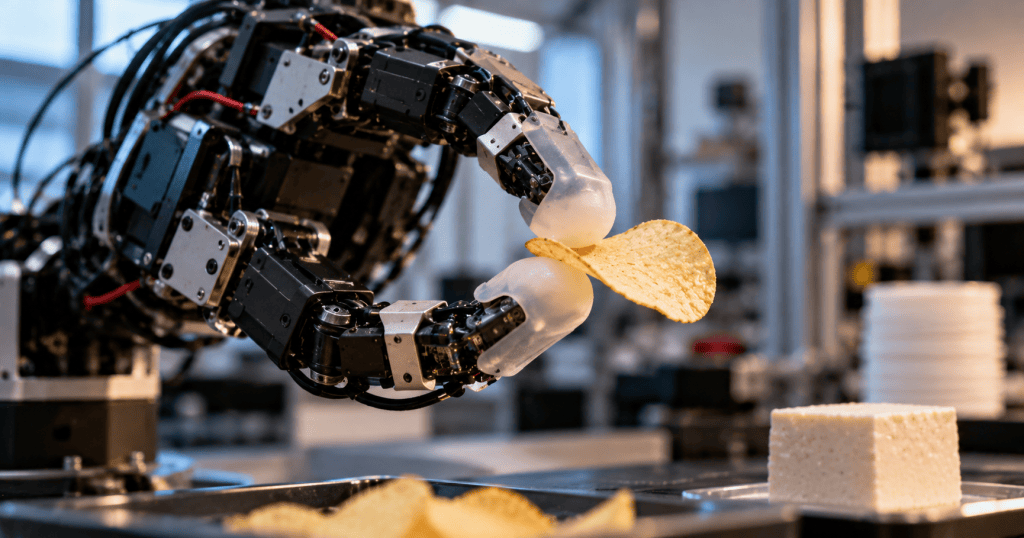
Carnegie Mellon researchers built robotic fingertips that combine force sensing, vibration sensing, a plastic fingernail, and silicone skin to handle fragile objects and detect slip.
-
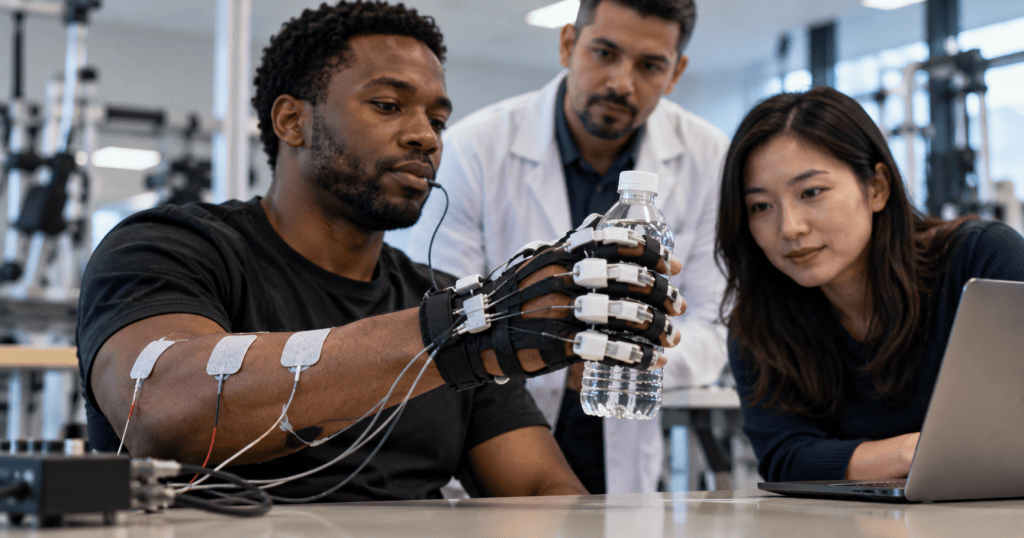
A tongue-controlled robotic hand exoskeleton combined with functional electrical stimulation reached 96% task success in five people with cervical spinal cord injury.
-
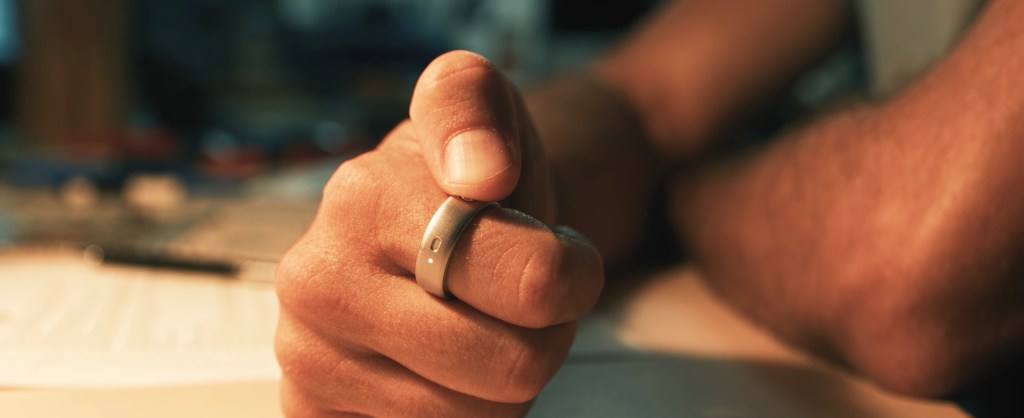
Natura’s $99 Interface smart ring uses a press-and-speak gesture to route requests to AI agents while also tracking sleep, heart rate, HRV, and movement.
-
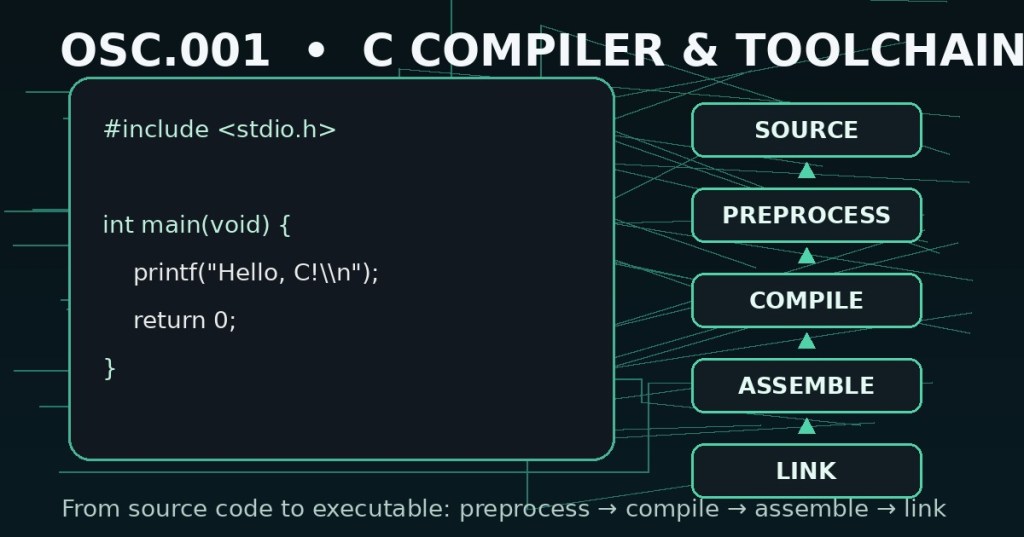
OSC.001 introduces the C compiler toolchain: GCC, preprocessing, compilation, assembly, linking, object files, first builds, warnings, and basic troubleshooting.
-
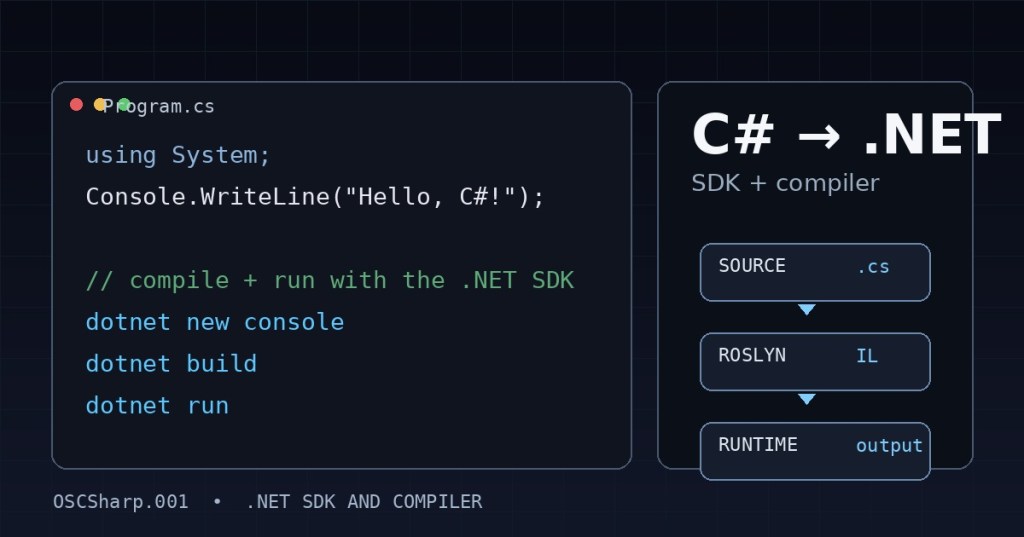
OSCSharp.001 introduces the C# toolchain: the .NET SDK, dotnet CLI, project creation, build/run workflow, Roslyn compiler, IL, runtime execution, and first troubleshooting steps.
-
OSLTC.003 teaches leadership through listening: active listening, adaptive feedback, communication preferences, responding to what people say, and turning listening into trust and action.
-
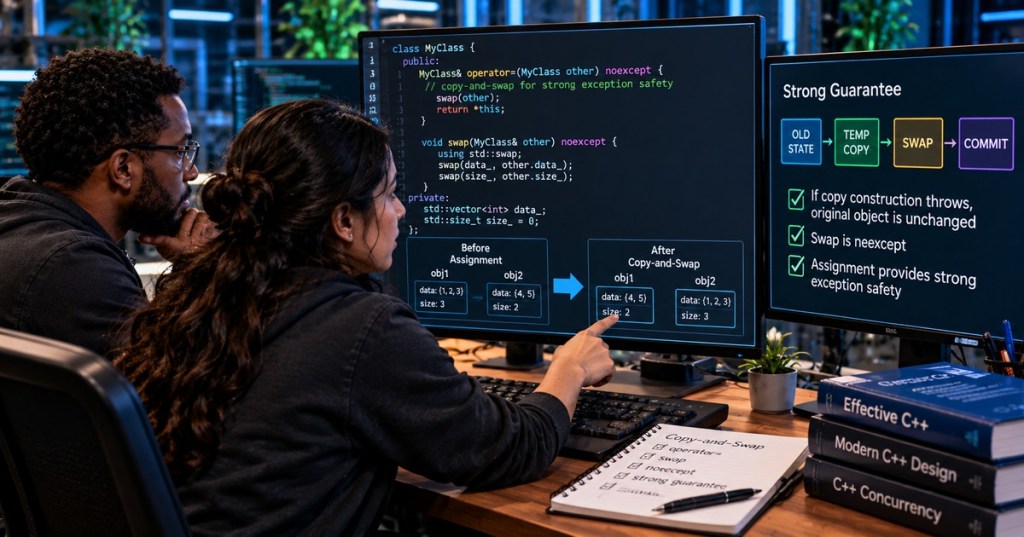
OSC++.025 teaches copy-and-swap and exception-safe C++ assignment: strong guarantees, noexcept swap, self-assignment, pass-by-value assignment, Rule of Zero, and performance tradeoffs.
-
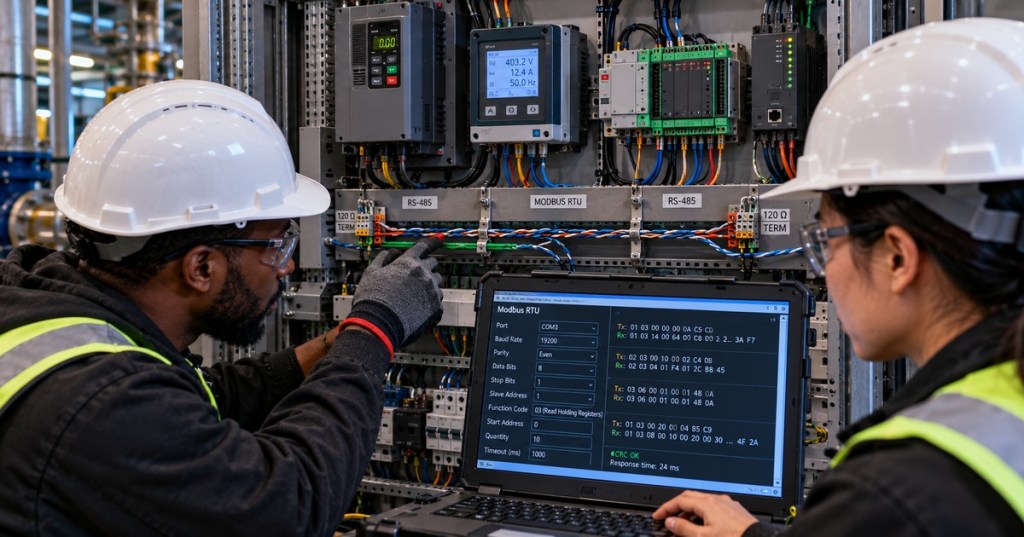
OSETC.032 teaches Modbus RTU over RS-485: two-wire bus wiring, termination, serial settings, addressing, function codes, registers, CRC, offsets, and field troubleshooting.
-
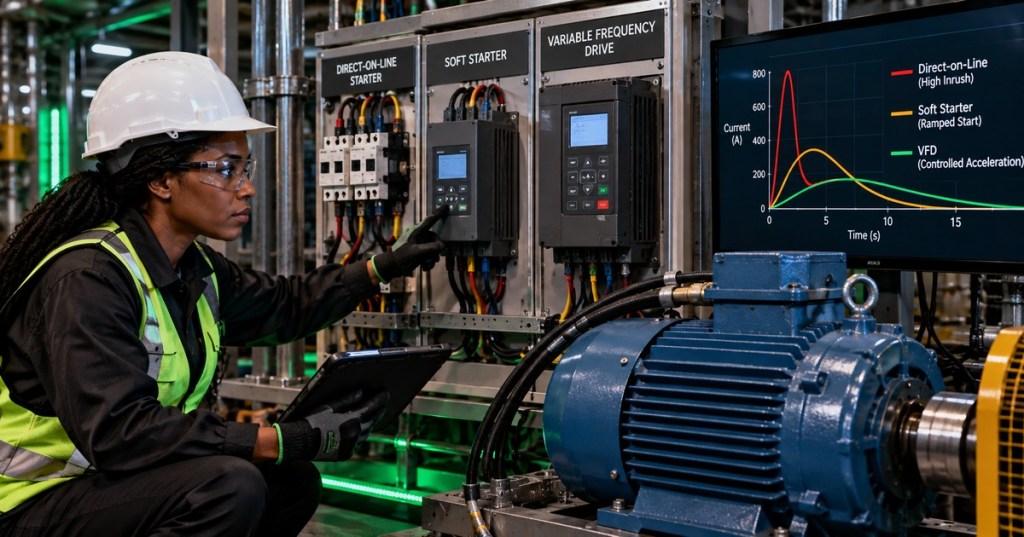
OSEEC.017 teaches motor starting engineering: inrush and locked-rotor current, source voltage dip, DOL starting, soft starters, VFDs, torque limits, starter selection, and commissioning measurements.
-
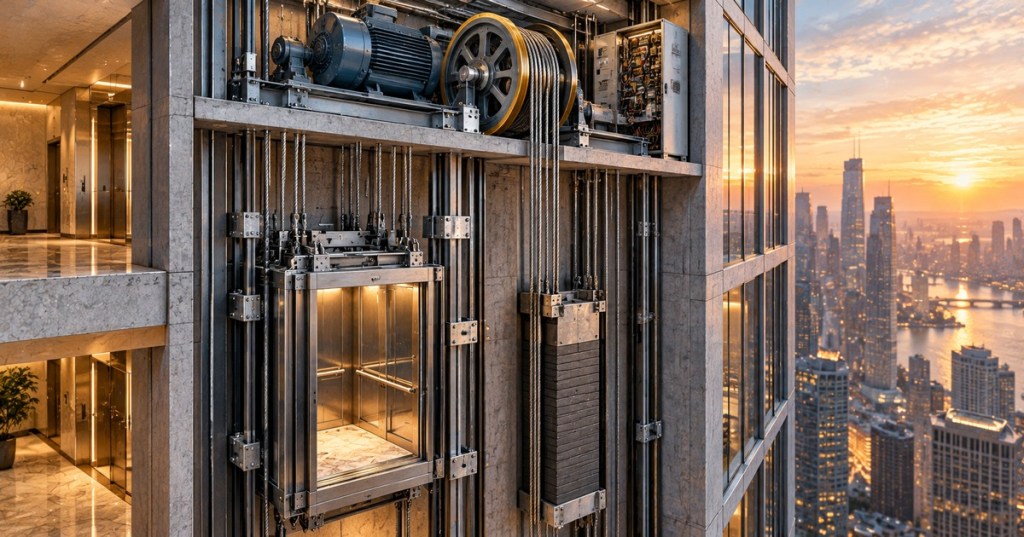
Modern elevators are coordinated electromechanical systems built around a car, counterweight, motor, traction sheave, rails, brakes, sensors and a controller. Here’s how all of those pieces work together.

