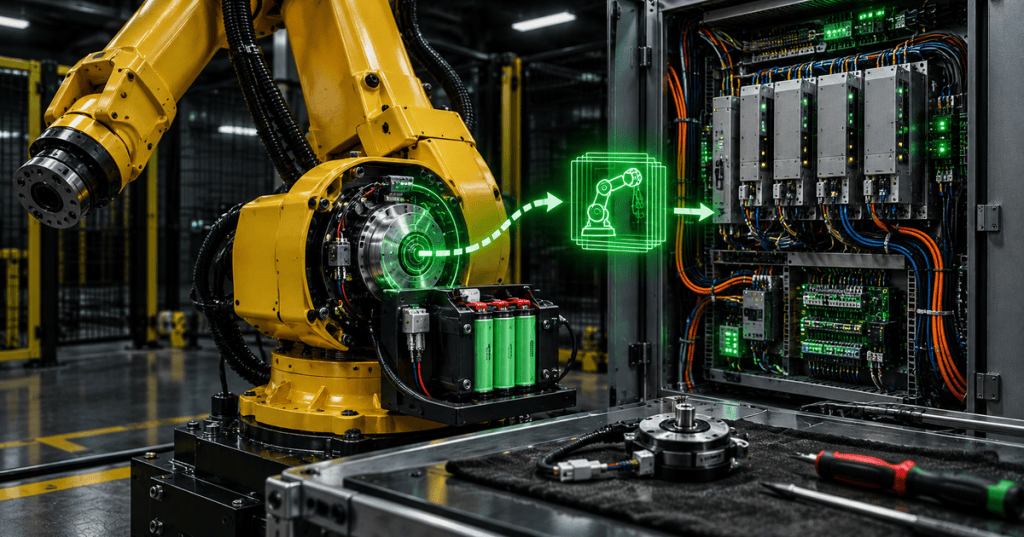
Industrial robots often depend on backup batteries to preserve encoder position information, mastering references, controller memory, or other retained data when normal power is removed. For a technician, the difficult part is not identifying a battery. The difficult part is knowing which data that battery protects, what power state the manufacturer requires during replacement, what can be lost if the sequence is wrong, and how to verify the robot afterward.
This lesson follows OSRTC.009: Robot Controller Backup and Restore, OSRTC.007: Robot Preventive Maintenance, and OSRTC.003: Robot Mastering and Calibration. Those lessons explain why backups, preventive maintenance, and mastering all meet at the battery-service task.
DENSO Robotics demonstrates encoder-battery replacement on an HSR robot with an RC8 controller.
Elementary Overview
An industrial robot must know where each joint is. Many systems retain some of that position information with battery-backed encoder electronics. Separate batteries may also preserve controller SRAM or other memory. If the wrong battery is allowed to die—or is disconnected under the wrong conditions—the robot may lose position counts, mastering information, programs, variables, or other retained state.
The critical rule is simple: there is no universal robot-battery replacement sequence. Battery type, location, replacement interval, required controller power state, emergency-stop state, sequence, allowed disconnect time, and verification steps are manufacturer-, controller-, and model-specific.
Learning Objectives
- Explain why industrial robots use encoder and controller backup batteries.
- Distinguish an encoder or pulsecoder battery from a controller-memory battery.
- Explain why battery-replacement power-state rules differ among robot families.
- Recognize the relationship between battery loss, encoder counts, mastering, and controller recovery.
- Prepare a safe pre-service checklist without inventing a generic replacement sequence.
- Identify evidence that a battery problem has already affected retained data.
- Know what must be verified before returning a robot to production.
Two Different Problems Can Be Called “The Robot Battery”
A technician should first determine what the battery actually backs up. An encoder or pulsecoder backup battery preserves position-related information associated with servo feedback. If that retained count is lost, the controller may no longer know how the encoder count corresponds to the physical joint position, and remastering or another recovery procedure may be required.
A controller-memory battery protects retained controller data when main power is removed. Depending on the controller generation, that can include SRAM-based programs, variables, or system information. Losing this battery can create a different failure from losing encoder backup power. The recovery path may involve restoring data rather than—or in addition to—remastering the mechanical unit.
Do not assume that one battery pack protects both functions. Some robots have separate batteries in the robot base, arm, encoder circuits, or controller cabinet.
Why Power-State Instructions Must Stay Model-Specific
Manufacturer procedures can require opposite controller power states. FANUC’s Changing Batteries training emphasizes maintaining the conditions needed to preserve encoder counts and mastering data during replacement. FANUC’s CRX battery training likewise tells technicians to maintain controller power during the pulsecoder-battery procedure for those models.
DENSO illustrates why technicians must not copy that rule blindly. Its VP-series procedure specifically says the controller must remain powered during encoder-battery replacement, while its HS-series procedure instructs the technician to turn controller power off. Both are valid for their specified robot families.
The lesson is not “leave power on” or “turn power off.” The lesson is “read the exact procedure for the exact robot.”
A PLC community discussion shows why battery-backed encoder counts matter in real robot maintenance and how losing them can turn a simple service task into a remastering job.
Emergency Stop, Controller Power, and Energy Isolation Are Not the Same Thing
An emergency stop can remove or inhibit motion energy while control electronics remain powered. A main disconnect or lockout can remove electrical power from the controller. Those states are not interchangeable. Some manufacturer-approved battery procedures intentionally require control electronics to remain energized so retained encoder information is not lost.
That does not mean a technician should improvise energized work. If the OEM procedure requires controller power during a battery task, the workcell risk assessment, manufacturer instructions, plant rules, required PPE, access restrictions, and technician qualification must all support that method. If the task cannot be performed under the approved procedure, stop and escalate.
Likewise, never assume pressing E-stop is equivalent to complete hazardous-energy isolation. Robot systems may contain gravity loads, stored mechanical energy, pneumatic or hydraulic pressure, external axes, process equipment, and live electrical circuits even when servo motion is disabled.
Low-Battery Alarms Are Early-Warning Evidence
Battery alarms should be treated as maintenance evidence, not nuisance messages. A warning means the robot may still be retaining its data today but could lose that data during a later power interruption if the backup source becomes too weak.
When a battery warning appears, record the exact alarm code and text, robot model, controller model, power state, recent power-cycle history, and whether the robot is currently mastered and producing correctly. Then check the OEM maintenance manual before cycling power or disconnecting anything.
This matters because a weak battery plus an unnecessary power cycle can convert a maintenance warning into data loss. Preserve evidence first.
Backup Before Battery Service
Before battery service, create the vendor-recommended controller backup whenever the procedure and machine condition permit. OSRTC.009 explains why the copy should include identity, controller generation, software version, date, and known-good status.
A controller backup does not necessarily preserve the live encoder count in a way that eliminates remastering risk, but it protects programs, system information, frames, variables, and other recoverable data. It also provides a baseline for comparison if something changes during maintenance.
A Technician Pre-Service Framework
- Identify the exact robot model, mechanical unit, controller model, software generation, and serial number.
- Read the current OEM maintenance procedure for that exact combination.
- Determine whether the target battery protects encoder position, controller memory, or another retained function.
- Record all active battery, encoder, servo, and mastering-related alarms before changing anything.
- Confirm the robot is currently mastered and note a trusted reference position when site procedure permits.
- Create and verify the appropriate controller backup.
- Verify the exact replacement battery part number, chemistry, polarity, quantity, and expiration condition.
- Confirm the OEM-required controller power, servo/motion, E-stop, and energy-control state.
- Identify whether the procedure imposes a maximum disconnected time or one-battery-at-a-time sequence.
- Stage tools and replacement batteries before opening the battery compartment.
- Do not begin if any required instruction, part number, power state, or safety condition is unclear.
Encoder Battery Service: What the Technician Is Protecting
The encoder system relates electrical feedback to physical joint position. On battery-backed systems, retained multi-turn or count information can be necessary for the controller to know where a joint is after normal power is removed. If backup power disappears at the wrong time, the controller can lose that retained relationship.
The visible result can be a battery alarm, encoder alarm, mastering alarm, invalid position condition, inability to jog normally, or a position that no longer agrees with the physical witness marks. The exact alarm names differ by manufacturer.
A FANUC community discussion explains the practical relationship between pulsecoder backup power, encoder count retention, and mastering loss after power removal.
Controller-Memory Battery Service Is a Different Failure Mode
Controller-memory batteries protect retained electronic memory rather than joint position. FANUC R-30iB maintenance documentation, for example, describes a lithium battery backing SRAM that contains programs and system variables. That procedure includes a limited replacement window after controller power is removed and explicitly recommends making a backup before battery replacement.
The service lesson is broader than one controller family: identify what memory technology is being protected, how long it can remain unsupported, and which data must be backed up before the old battery is removed.
Do Not Mix Old and New Batteries Unless the OEM Says To
Some robot battery assemblies use multiple cells or packs. Manufacturer procedures may require all batteries in a set to be replaced together, may specify one-at-a-time replacement to preserve the circuit, or may provide a spare connector that lets a new pack be attached before the old one is removed.
Follow that sequence exactly. Mixing old and new cells can create uneven service life, and disconnecting the entire backup source at once can defeat the very protection the batteries are supposed to provide.
Polarity, Part Number, and Chemistry Matter
Use the exact battery specified by the OEM. A battery that physically fits is not automatically electrically or mechanically correct. Voltage, chemistry, connector pinout, polarity, temperature rating, leakage characteristics, capacity, mounting method, and certification can all matter.
Inspect the battery compartment for corrosion, leakage, damaged wiring, loose connectors, cracked holders, contamination, or heat damage. A new battery does not repair a failed holder or corroded contact.
If Mastering or Encoder Data Is Already Lost
Do not immediately reteach production points. First preserve the alarm state and determine whether the problem is battery-related, a disconnected encoder cable, replacement servo hardware, mechanical movement, or another fault. Then use the approved mastering recovery method from the OEM and the principles from OSRTC.003.
After mastering recovery, verify physical reference marks, user and tool frames, fixture relationships, TCP accuracy, payload data, collision or interference settings, and a known reference point before automatic production. Reteaching around a wrong mastering condition can hide the fault and make later recovery harder.
Post-Service Verification
- Confirm the new battery or battery set is installed exactly as specified.
- Confirm covers, connectors, seals, and fasteners are restored.
- Check that the original battery alarm is cleared for a known reason.
- Check for new encoder, servo, controller-memory, or mastering alarms.
- Confirm mastering status and compare a known reference position when applicable.
- Verify tool and user frames if there is any indication position reference was affected.
- Verify required I/O, safety, and communication functions before automatic operation.
- Jog or test motion only under the approved reduced-risk procedure.
- Run an approved dry cycle or reference check before returning the cell to production.
- Record the battery part number, replacement date, technician, alarms, power-state method, and verification result.
- Create a fresh post-maintenance backup after the robot is proven healthy.
Troubleshooting Pattern Recognition
- Low-battery alarm but robot still runs correctly: preserve data and follow the OEM replacement procedure before an uncontrolled power loss occurs.
- Battery changed, then mastering alarm appears: verify whether backup power was interrupted or the required sequence was violated before touching production points.
- Programs missing but joint position appears normal: investigate controller-memory retention and restore scope rather than assuming an encoder problem.
- Joint position is wrong after power cycle: investigate encoder count retention, mastering state, encoder cabling, and mechanical reference.
- New battery alarm remains active: verify battery part number, polarity, connector seating, battery voltage, holder condition, and whether the alarm requires an approved reset or restart step.
- One robot model says power ON and another says power OFF: that is not a contradiction; it is evidence that the procedures are model-specific.
Hands-On Exercise
Use a training robot, simulator documentation set, or de-energized maintenance lab. Do not perform live battery service unless you are qualified and the exact OEM procedure authorizes it.
- Choose one robot model and locate its current mechanical-unit and controller maintenance manuals.
- Identify every battery associated with the robot and write down what each battery protects.
- Record the specified replacement interval and exact battery part number.
- Record the required controller power, servo state, E-stop state, and energy-control conditions.
- Identify any maximum disconnect time, one-at-a-time rule, or spare-connector method.
- List the alarms associated with low battery or lost position retention.
- Write the required verification sequence after replacement.
- Compare that procedure with a second robot family and identify at least three differences.
- Explain why copying the first procedure onto the second robot could cause a failure.
Knowledge Check
- What is the main purpose of an encoder backup battery?
- How is a controller-memory battery different?
- Why is there no universal rule for whether controller power should be on or off during battery replacement?
- Why should a low-battery alarm be handled before an unnecessary power cycle?
- Does an E-stop always mean all electrical energy is isolated?
- Why should a verified controller backup be created before service?
- Why can losing encoder backup power lead to remastering?
- What should a technician do if the OEM battery procedure is unclear?
- Why should a robot be checked at a known reference position after service?
- What should be documented after a successful battery replacement?
Answers
- To preserve the retained encoder or position information required to relate feedback counts to physical joint position when normal power is removed.
- It protects retained controller data such as SRAM-based programs, variables, or system information rather than joint-position counts.
- Robot electrical architectures differ, and manufacturers specify different safe sequences for different mechanical units and controllers.
- The robot may still be retaining valid information; a power loss with a weak battery can turn a warning into data loss.
- No. E-stop can disable motion while control electronics or other hazardous energy remain present.
- To preserve programs, configuration, frames, variables, and other recoverable controller state if the service task goes wrong.
- Battery-backed encoder counts may be part of the controller’s reference between encoder feedback and physical joint position.
- Stop and obtain the correct current OEM procedure or escalate to qualified support.
- To prove that retained position and mastering still agree with the physical machine before automatic production.
- Battery part number, date, technician, alarms, required power-state method, findings, verification results, and the new backup status.
Primary References
- FANUC America — Changing Batteries
- FANUC America — CRX Changing Batteries
- DENSO Robotics — HS Series Encoder Battery Replacement
- DENSO Robotics — VP Series Encoder Battery Replacement
Elementary Conclusion
Robot battery service protects information that the machine may need to know where it is and how it is configured. The technician’s job is to identify exactly what the battery protects, preserve the current state, follow the exact model-specific power and replacement procedure, and prove the robot is still correctly mastered and configured afterward. Battery replacement is a data-retention task as much as it is an electrical maintenance task.
Next: OSRTC.011 will continue the industrial robot field-service sequence.
Safety: industrial robot battery procedures can involve live controller electronics, stored mechanical energy, servo systems, and machine hazards. Power-state requirements vary by model. Follow the exact OEM manual, workcell risk assessment, facility energy-control procedure, and qualification requirements. Never improvise an energized battery-replacement method.


Leave a Reply