Elementary Overview
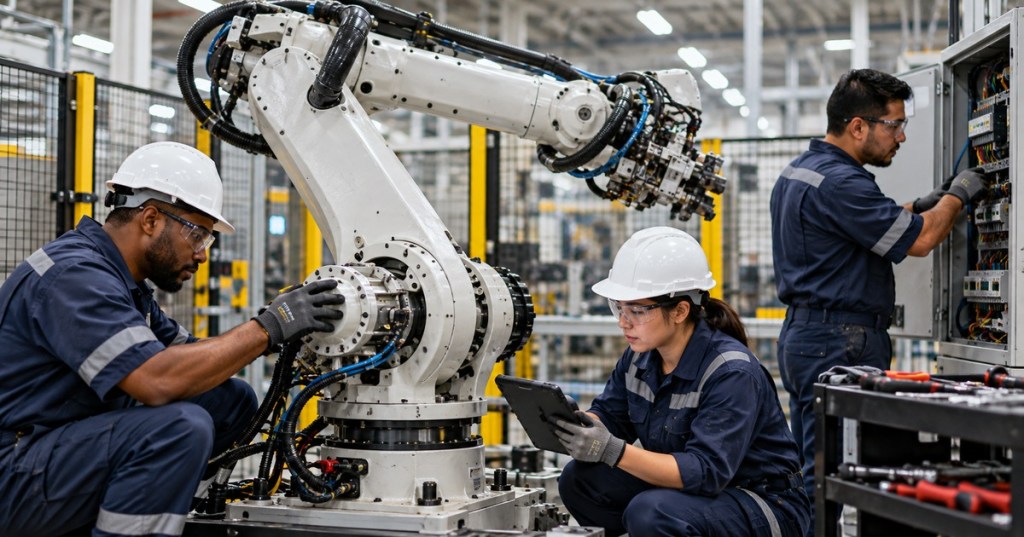
Preventive maintenance is planned work performed before a robot fails. The goal is not to replace parts on a calendar simply because time passed. The goal is to keep the mechanical unit, controller, cabling, feedback system, tooling, safety system, and software baseline inside the condition expected by the manufacturer and the workcell design.
This lesson follows OSRTC.006: Robot Alarm and Fault Recovery. Fault recovery teaches what to do after evidence of a problem appears. Preventive maintenance moves the same evidence-first thinking earlier: inspect, trend, document, and correct deterioration before it becomes an unplanned stop.
Start With The OEM Schedule, Not A Generic Interval
Robot maintenance intervals are model-specific and application-specific. A welding robot exposed to heat, metal dust, spatter, and a demanding duty cycle may need different attention than a lightly loaded material-handling robot in a clean environment. The correct starting point is the exact mechanical-unit and controller maintenance documentation for the robot model, then the plant can add inspections based on environment, duty cycle, failure history, and criticality.
FANUC America’s maintenance guidance separates frequent visual checks from production-based timed reviews and specifically calls out robot hardware, fluid condition, batteries, controller cleanliness, software backups, and trend data. ABB likewise describes preventive maintenance as scheduled service that can include inspection, adjustments, lubrication, and condition-based analysis. The technician should therefore treat the OEM interval as the minimum structured baseline, not as permission to ignore changing condition between scheduled visits.
Safety Comes Before Mechanical Access
Hands-on maintenance begins with the workcell risk assessment and the applicable energy-control procedure. A robot may contain electrical energy, stored mechanical energy, gravity loads, pneumatic or hydraulic pressure, spring forces, tooling hazards, external axes, and process energy. Use the same discipline established in OSRTC.001 and OSETC.011 on lockout/tagout.
Do not assume that pressing an emergency-stop button makes every maintenance task safe. The approved procedure must account for all hazardous energy sources and for tasks that require energized diagnostics. Any energized work must follow the manufacturer instructions, facility rules, and qualification requirements for that task.
A Good PM Begins With A Baseline Inspection
A strong inspection compares the robot with a known-good baseline. Look for loose or missing fasteners, damaged covers, fluid seepage, cracked seals, unusual contamination, loose connectors, worn cable jackets, damaged dress packs, abnormal hose routing, tool damage, fixture movement, and evidence of impact. Listen during normal production for new grinding, clicking, air leaks, squeal, or vibration.
The key is change. A stain that has been dry and unchanged for months means something different from fresh oil appearing after every shift. A cable with stable cosmetic wear is different from insulation that is progressively flattening at the same bend point. Maintenance records make those differences visible.
ABB Robotics — official overview of scheduled preventive maintenance for industrial robots.
Lubrication Is A Procedure, Not Just Adding Grease
Robot joints and gearboxes depend on the lubricant specified for that mechanical unit. The maintenance task may involve checking level or condition, replenishing lubricant, replacing grease or oil, placing the robot in a prescribed posture, opening the correct outlet or vent, and relieving residual pressure exactly as the OEM procedure requires. The wrong lubricant, wrong quantity, wrong port, or wrong pressure condition can create leaks, damaged seals, poor lubrication, or inaccurate service records.
Never transfer a grease interval from one robot family to another. Some maintenance intervals are based on elapsed time, operating hours, duty cycle, or environmental severity. Record the robot model, axis or gearbox serviced, lubricant specification, quantity if required by the OEM procedure, date, operating hours, technician, and any abnormal material observed.
Backlash, Noise, And Position Shift Are Mechanical Evidence
Mechanical wear often appears first as a change in repeatability, backlash, sound, vibration, temperature, or required motor effort. A technician should not compensate for a developing mechanical problem by simply reteaching points. If a process begins drifting, compare the robot’s mastering and reference condition using the methods from OSRTC.003, then inspect tooling, fixtures, joint condition, couplings, reducers, mounting hardware, and payload data.
A position error after maintenance can come from lost mastering, but it can also come from a loose tool, shifted fixture, damaged reducer, incorrect payload, or physical movement of the robot base. Maintenance should preserve evidence instead of masking it with program edits.
Batteries Protect Position And Configuration Data
Many industrial robots use backup batteries to preserve encoder or position-reference information and may use separate controller batteries for memory or other retained data. A low-battery alarm is therefore a maintenance warning, not a cosmetic message. Losing the required backup source at the wrong time can turn a simple battery task into a mastering or configuration-recovery event.
Battery type, replacement interval, controller power state, emergency-stop state, and replacement sequence are controller- and model-specific. Follow the exact OEM procedure. Do not generalize one robot’s battery-change method to another robot family.
Inspect Cables Where Motion Repeats
Robot cabling fails where flexing, abrasion, contamination, heat, strain, or poor routing concentrates stress. Inspect dress packs, encoder and motor cables, end-effector cables, air lines, fieldbus wiring, and connectors at known bend points and transition locations. Look for flattened jackets, exposed braid, cracked conduit, pulled strain relief, loose connectors, coolant intrusion, burn marks, or repeated rubbing against the arm or fixture.
Intermittent cable faults can appear as servo alarms, encoder faults, I/O dropouts, or process-device failures. Use the signal-path reasoning from OSRTC.005: inspect the physical path, then verify the electrical or logical signal at each layer before replacing major hardware.
Controller Cleanliness Protects Electronics
Cooling fans, filters, heat exchangers, cabinet seals, cable-entry covers, and clean airflow matter because power electronics and control hardware depend on temperature and contamination control. Dust, oil mist, conductive particles, blocked airflow, and failed fans raise component temperature and can increase failure risk.
Inspect the controller environment as a system. Replacing a clogged filter is useful, but it does not solve a damaged door seal that continually draws contamination into the cabinet. Likewise, a recurring fan alarm belongs in the evidence chain taught in OSRTC.006.
Back Up The Controller Before You Need The Backup
A preventive-maintenance program should include verified controller backups. Programs, frames, tool data, payload data, I/O configuration, calibration information, variables, communication settings, and application files may all matter during recovery. A backup that has never been tested or cannot be associated with a known machine state is weaker than a documented backup tied to the robot serial number, software version, date, and change record.
Backups also make troubleshooting safer. If a configuration changes during service, the technician can compare the current state with a known-good baseline instead of relying on memory.
Condition-Based Maintenance Uses The Robot’s Own Data
Scheduled maintenance asks, “What should be serviced at this interval?” Condition-based maintenance adds a second question: “What is this specific robot telling us about its condition?” Useful evidence can include alarm history, duty factor, axis loading, motor or reducer health indicators, temperatures, vibration, cycle counts, collision events, servo behavior, and repeated deviations from a known baseline.
ABB’s Condition-Based Maintenance service analyzes robot motion cycles and usage to identify highly stressed robots and prioritize maintenance. FANUC’s Zero Down Time platform similarly uses robot condition and performance data to identify potential problems before they affect production. These systems do not eliminate technician judgment; they improve where the technician looks first.
ABB Robotics — official condition-based maintenance overview showing how robot usage data can guide maintenance priorities.
The same predictive-maintenance principle is increasingly being paired with sensor-rich digital twins across engineering. The University of Hyderabad highlighted predictive maintenance, structural health monitoring, autonomous systems, sensors, and real-time controllers in its digital-twin research facilities.
University of Hyderabad — digital-twin research infrastructure connecting sensors, autonomous systems, and predictive-maintenance applications.
Use Maintenance Records As Diagnostic Data
A maintenance record should let the next technician reconstruct the condition of the robot. Record the robot identifier, controller type, software version when relevant, operating hours or cycle count, maintenance reason, inspection findings, parts and consumables used, alarms observed, measurements taken, backups created, corrective actions, and verification results.
Trend repeated findings. If the same axis repeatedly shows contamination, abnormal sound, higher temperature, or cable damage, the pattern may reveal a routing, duty-cycle, environment, or mechanical problem. This is the same reliability logic used in reliability engineering: maintenance history becomes evidence for root-cause analysis and better maintenance planning.
Return To Service Requires Verification
Preventive maintenance is not complete when the tools are put away. The robot must be returned to service through an approved verification sequence. Confirm guards and covers are restored, tools and loose hardware are removed, connections are secure, safety devices are functional, alarms are cleared for a known reason, mastering or reference checks remain valid, end-effector operation is correct, and required I/O handshakes return to normal.
When motion verification is required, use the approved reduced-risk procedure before restoring full automatic production. Compare the robot’s behavior with the pre-maintenance baseline. If the work changed tooling, payload, TCP, or calibration, verify the setup using the methods from OSRTC.004.
Practical Preventive-Maintenance Checklist
- Identify the exact robot, controller, software version, tooling, and applicable OEM maintenance documents.
- Review alarm history and the previous maintenance record before opening the cell.
- Apply the workcell risk assessment and required energy-control procedure.
- Inspect robot hardware, fasteners, covers, seals, leakage, contamination, cables, hoses, tooling, fixtures, and dress packs.
- Listen and observe the robot during normal operation when safe and permitted; note new sound, vibration, heat, or motion behavior.
- Perform lubrication, battery, filter, fan, cable, and other scheduled tasks only according to the exact OEM procedure for that model.
- Verify backups and preserve a known-good controller configuration before significant changes.
- Review condition data, alarms, duty cycle, and recurring findings for evidence of developing failure.
- Document parts, consumables, observations, measurements, and any corrective work.
- Restore covers, guarding, connectors, and safety devices.
- Perform approved functional and reduced-risk motion verification.
- Confirm the robot returns to automatic production without new alarms, position shift, I/O problems, or abnormal behavior.
Technician Pattern Recognition
- Fresh oil or grease around one joint: document the location and condition, then follow the OEM inspection procedure instead of simply wiping it clean.
- Recurring cable fault at one pose: inspect dress-pack routing, bend radius, strain, and rubbing at that position.
- Position shift after maintenance: check tooling, fixtures, mechanical coupling, mastering, and reference data before reteaching points.
- Controller running hotter than normal: inspect fans, filters, airflow, contamination, ambient conditions, and alarm history.
- Battery warning: preserve the controller and position data by following the exact model-specific replacement procedure.
- Same axis develops repeated alarms: compare maintenance history, duty cycle, cables, feedback, drive evidence, and mechanical condition instead of treating each alarm as unrelated.
- Robot passes scheduled PM but fails repeatedly between visits: add condition-based monitoring and reassess the maintenance interval or application stress.
Exercises
- Create a pre-PM inspection sheet for a six-axis industrial robot that separates visual, mechanical, electrical, software, safety, and tooling observations.
- Explain why lubrication procedures must remain robot-model specific.
- Describe how a worn dress pack could produce intermittent I/O or encoder faults only at certain poses.
- Build a maintenance record that would allow another technician to compare robot condition six months later.
- List the evidence you would collect before deciding that a position shift requires remastering.
- Explain the difference between time-based preventive maintenance and condition-based maintenance.
- Design a return-to-service verification sequence after routine PM without assuming that an emergency stop alone provides energy isolation.
Knowledge Check + Answers
- What defines the correct maintenance interval? The exact OEM documentation for the robot and controller, adjusted by approved plant practices for duty cycle, environment, history, and criticality.
- Why is a generic grease interval unsafe? Robot families can use different lubricants, quantities, service postures, ports, pressure-release steps, and intervals.
- Why are backup batteries important? They may preserve encoder, mastering, memory, or configuration information that can be lost if the required backup source is removed incorrectly.
- What is the best indicator during a visual inspection? Change from a known-good baseline: new leakage, new wear, new vibration, new contamination, or a worsening trend.
- Why are controller backups part of PM? They preserve a recoverable known-good software and configuration state before a failure or maintenance change.
- What does condition-based maintenance add? It uses actual robot usage and health data to prioritize attention based on condition rather than time alone.
- When is PM complete? After the work is documented and the robot passes the approved safety, configuration, I/O, tooling, and motion verification needed to return to production.
Prior Lessons And Primary References
- OSRTC.006 — Robot Alarm and Fault Recovery
- OSRTC.005 — Robot I/O and PLC Handshakes
- OSRTC.004 — End Effectors and Tool Center Point Setup
- OSRTC.003 — Robot Mastering and Calibration
- OSRTC.001 — Industrial Robot Safety
- FANUC America — 13 Steps to Better Arc Welding Robot Maintenance
- FANUC America — Robot Service and Preventive Maintenance
- FANUC America — Zero Down Time Predictive Maintenance
- ABB Robotics — Maintenance
- ABB Robotics — Condition-Based Maintenance
Elementary Conclusion
Robot preventive maintenance is disciplined evidence collection plus model-specific service. Inspect for change, protect safety and stored data, service lubrication and batteries exactly as the OEM specifies, track cable and controller condition, maintain verified backups, and use robot health data to find deterioration before it becomes downtime. The best maintenance program does not merely prove that a checklist was completed. It proves that the robot returned to service in a known, documented, and technically verified condition.
BitcoinVersus.Tech
Advertisement
BitcoinVersus.Tech publishes open technical education across robotics, electrical systems, programming, semiconductors, networking, data centers, firmware, and industrial technology.
Editor’s Note
Maintenance intervals, lubrication specifications, battery procedures, grease-release procedures, energized diagnostics, brake release, calibration, torque values, and replacement methods are manufacturer-, controller-, and model-specific. Follow the exact OEM manual, workcell risk assessment, and facility energy-control procedure. Maintenance involving hazardous electrical or stored mechanical energy is for qualified personnel operating under approved procedures.
We volunteer daily to help keep the information on this platform verifiably accurate. Support our independent research through the support options available on BitcoinVersus.Tech.
BitcoinVersus.tech is not a financial advisor. Content is provided for informational purposes.


Leave a Reply