Trossen Robotics and Stereolabs are combining bimanual robot hardware, synchronized stereo vision and onboard NVIDIA compute into a ready-to-use physical AI data-collection stack.
The companies say Stereolabs ZED X Mini and ZED X Nano cameras are being integrated directly into Trossen’s Workbench and Rivet platforms. The goal is to remove the calibration, synchronization and cabling work that robotics teams often have to solve before they can collect useful training data.
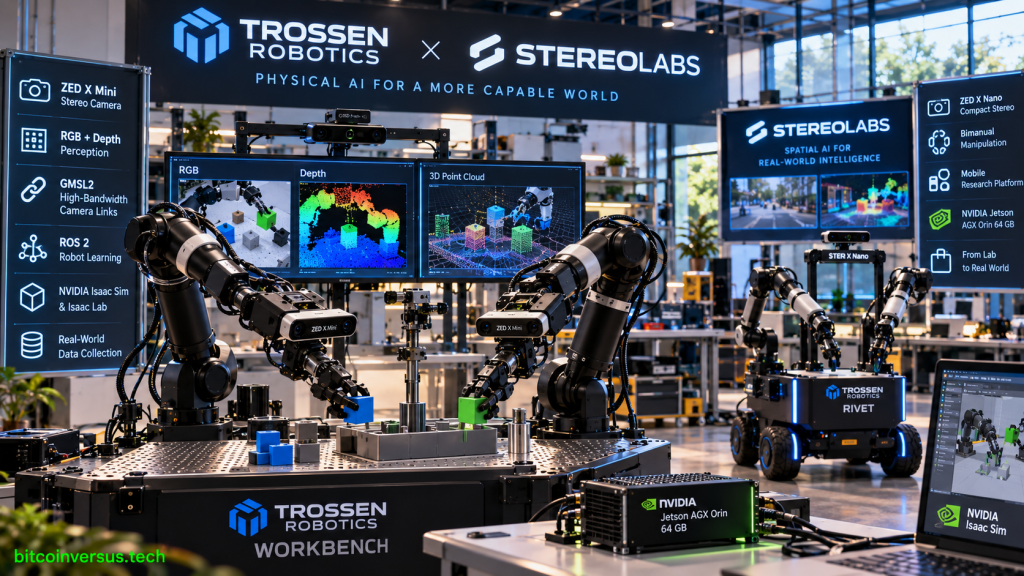
The stationary Workbench and mobile Rivet each use dual WidowX Pro six-degree-of-freedom arms. According to industry reporting, the arms offer 700 to 1,000 millimeters of reach, 4 to 6 kilograms of payload capacity and 1-millimeter repeatability. Both platforms use an onboard NVIDIA Jetson AGX Orin 64 GB computer, connecting this hardware to the broader NVIDIA Isaac robotics ecosystem.
Vision is where the partnership becomes especially relevant to robot learning. A center-mounted ZED X Mini records the wider workspace while wrist-mounted ZED X Nano cameras capture close-range views around the grippers. The Nano uses dual 2.3-megapixel global-shutter sensors at up to 60 frames per second and can resolve depth from about 3 centimeters, giving manipulation policies detailed RGB-plus-depth observations.
The cameras connect over GMSL2 rather than ordinary consumer USB. That matters because robot arms introduce longer cable paths, motion and electrical noise. Stereolabs and Trossen say the synchronized zero-copy pipeline lets the Jetson record, encode and run inference without silently dropping frames. The same focus on reliable perception is driving deals elsewhere in robot vision hardware.
Every teleoperated episode can therefore become a synchronized multi-view RGB-plus-depth training sample. The platforms support ROS 2 as well as NVIDIA Isaac Sim and Isaac Lab, linking real demonstrations to imitation learning, reinforcement learning and sim-to-real workflows. That puts the hardware alongside a growing wave of physical AI systems, robotics software integration and edge AI processors.
Trossen’s broader lineup also includes Glide leader arms and the Cockpit operator station for teleoperation. Workbench keeps the manipulation setup fixed for repeatable data collection, while Rivet moves the same two-arm architecture onto a mobile base. That continuity is intended to reduce the amount of hardware and software rebuilding required when a policy moves from the lab into a room, warehouse or factory.
The collaboration is another sign that the physical AI bottleneck is shifting from simply building smarter models toward collecting cleaner real-world data. BitcoinVersus.tech has recently tracked the same transition through new physical AI investment and the rapidly expanding market for industrial robots.
Follow BitcoinVersus.tech on X
Editorial note: BitcoinVersus.tech covers the intersection of Bitcoin, technology, computing, energy and emerging infrastructure. This report is based on publicly available reporting and company disclosures.
Disclaimer: This article is for informational purposes only and is not financial or investment advice.


Leave a comment