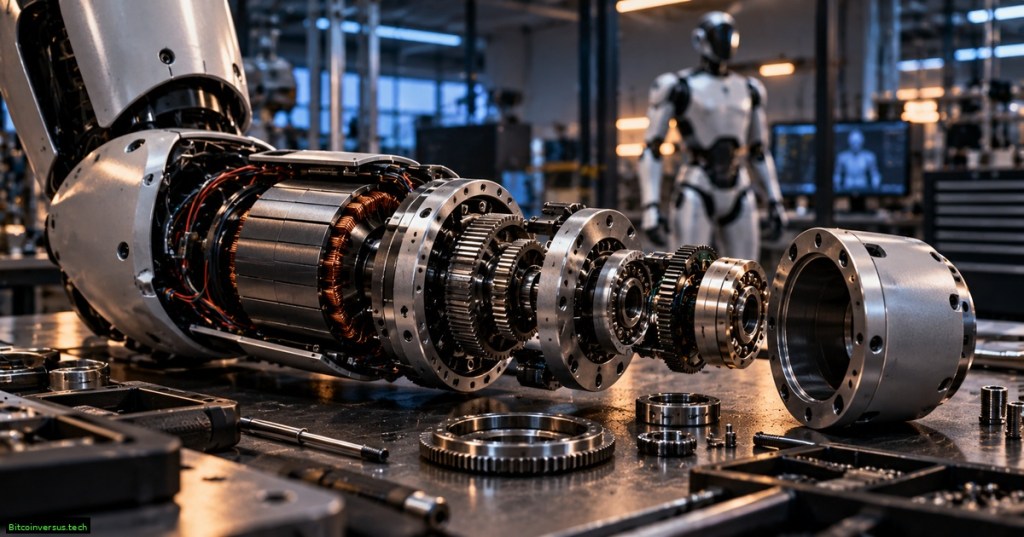
Humanoid robotics is usually framed as an artificial-intelligence race, but the most expensive part of the machine is still mechanical. McKinsey estimates that actuation accounts for roughly 40–60% of a humanoid robot’s bill of materials, far more than compute, sensing, structure, or batteries.
That makes the actuator—the motor, gearbox or reducer, encoder, bearings, driver electronics, and joint hardware that turn electrical energy into controlled motion—the real hardware bottleneck behind the humanoid boom. A robot can have world-class AI and still fail commercially if its joints are too expensive, too heavy, too inefficient, or impossible to manufacture at volume.
The Joint Is the Expensive Part
McKinsey’s current humanoid supply-chain analysis places actuators at 40–60% of total BOM cost, followed by sensing and perception at roughly 10–20% and compute/control at about 10–15%. Schaeffler, one of the major motion-technology suppliers moving into humanoids, similarly says actuators can represent about half of the total BOM value in many designs.
A full-size humanoid may contain dozens of joints, each requiring a combination of torque density, low backlash, position sensing, thermal control, durability, and efficiency. That is why a small percentage reduction in actuator cost can move the economics of the entire robot more than a similar improvement in many other subsystems.
Actuators Are More Than Motors
The actuator stack usually combines an electric motor with a transmission such as a strain-wave reducer, planetary gearbox, cycloidal reducer, or linear screw mechanism. It may also integrate an encoder, torque sensor, bearings, power electronics, and local control electronics into one compact joint module.
Schaeffler’s humanoid roadmap now includes strain-wave, planetary, and cycloidal actuator architectures. Its planetary actuator combines a two-stage gearbox, electric motor, encoder, and controller into a single unit, while its newer formed strain-wave gearbox is aimed specifically at reducing manufacturing cost for humanoid-scale production.
Strain-Wave Reducers Are Hard to Scale
High-precision strain-wave reducers are popular because they deliver large reduction ratios in compact packages with extremely low backlash. The tradeoff is manufacturing difficulty: flexible splines, precision tooth geometry, heat treatment, and micron-scale machining all have to survive millions of motion cycles without cracking or drifting out of tolerance.
Recent supply-chain analysis reported by MarketWatch highlights a thin U.S. supplier base for high-volume humanoid actuators and precision reducers. The issue is not that the United States lacks precision-motion engineering; it is that much of the existing domestic capacity was built for aerospace, industrial automation, or automotive volumes and cost structures rather than tens of thousands of relatively low-cost humanoid joints.
Apptronik Is Designing Around Manufacturability
Apptronik says actuation is at the heart of its Apollo 2 humanoid and describes its actuator platform as more than 90% energy efficient, maintainable, mass-manufacturable, and designed for supply-chain resiliency. That language matters because industrial humanoids cannot scale on prototype-grade joints that require hand tuning or long-lead specialty components.
BitcoinVersus has already covered how companies are pushing humanoid hardware toward real deployment, from Agility’s Digit 5 to Unitree’s G1. The actuator supply chain determines whether those systems remain expensive demonstrations or become repeatable industrial products.
Why China Has an Advantage
China’s robotics ecosystem benefits from dense local supply chains for motors, reducers, bearings, encoders, castings, electronics, and machine tools. That shortens iteration cycles and makes it easier to redesign a joint without waiting months for a specialized imported component.
The competitive advantage is therefore not just cheap labor or government support. It is proximity between robot OEMs and the factories that make the robot’s “muscles.” When suppliers and engineering teams are geographically close, a new actuator geometry can move from CAD to sample hardware much faster.
The Hardware Race Is Really a Cost Curve
The next humanoid breakthrough may not be a new physical-AI stack. It may be a joint that delivers the same torque with fewer parts, less machining, lower mass, better thermal behavior, and half the cost. Schaeffler says its newer formed strain-wave process can cut production cost by more than 25% while sharply reducing material use, with series production targeted for 2027.
That is the key hardware metric to watch. If humanoid builders can push actuator cost down while preserving torque density, precision, efficiency, and lifetime, the entire robot becomes easier to manufacture. If they cannot, AI progress alone will not make humanoids cheap enough for mass deployment.
What to Watch Next
Watch actuator price per joint, torque-to-weight ratio, efficiency, reducer lifetime, backlash, supplier lead times, and the percentage of the robot BOM that can be sourced domestically. Those numbers will reveal more about humanoid manufacturing readiness than another impressive walking demo.
BitcoinVersus.Tech
Advertisement
Editor’s Note
The 40–60% actuator share is an industry estimate rather than a universal constant. Different humanoid architectures draw subsystem boundaries differently, and cost shares will change as production volume rises.
We volunteer daily to ensure the credibility of the information on this platform is Verifiably True. If you would like to support to help further secure the integrity of our research initiatives, please donate here: 3C9o19EH5HSiwEPyCTmEKzxhNCbo2X6TTb
BitcoinVersus.tech is not a financial advisor. This media platform reports on financial subjects purely for informational purposes.


Leave a Reply